Ph.D. Student · UCLA
Department of Computer Science, UCLA
Vision and Autonomy Intelligence Lab (VAIL)
Advisor: Prof. Bolei Zhou
I am a first-year Ph.D. student at UCLA, working on Physical AI, VLM, VLA, and Robotics. My research focuses on high-intelligence autonomous navigation in large-scale agricultural environments, integrating SLAM, semantic mapping, and vision-language-models for real-world deployment.
Ph.D. in Computer Science
Vision and Autonomy Intelligence Lab (VAIL)
Advisor: Prof. Bolei Zhou
Research Area: Robotics, Computer Vision, VLA Models
M.S. in Mechanical Engineering
Structures-Computer Interaction Lab
Advisor: Prof. M. Khalid Jawed
Research Area: Computer Vision, NeRF
CONNECTIVE Inc.
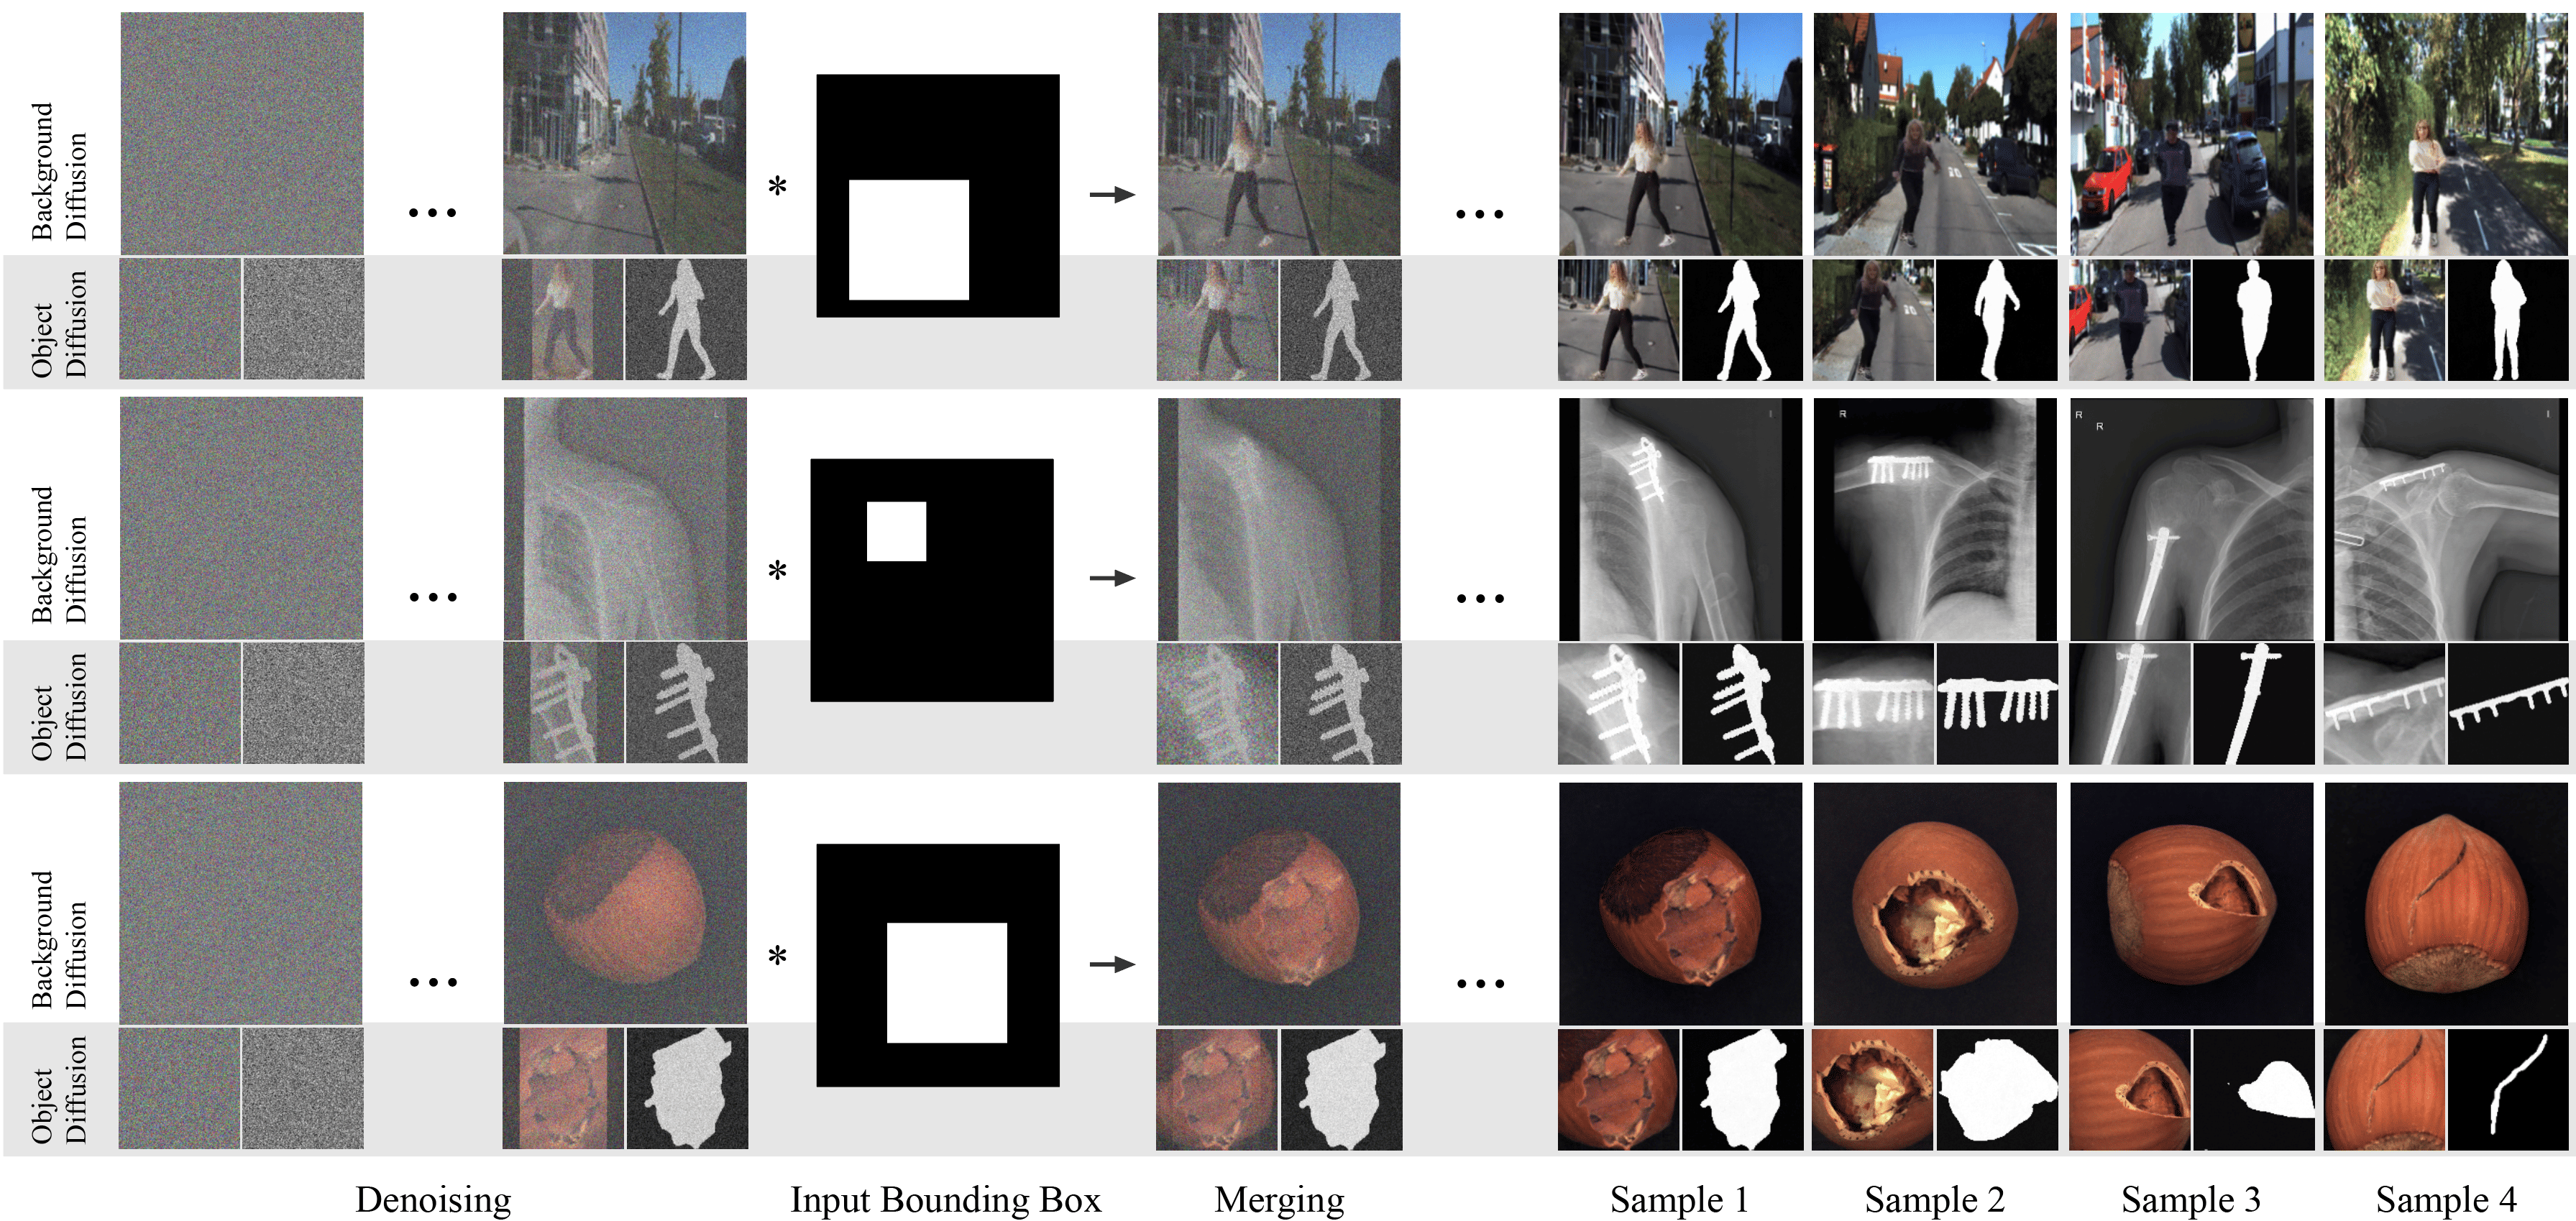
Designed a framework for composite image generation to address data scarcity in medical X-ray datasets
VRCrew Inc.
Developed a visual positioning system (VPS) for a VR application, estimating user location using mobile devices
Korea Institute of Science and Technology
Proposed a performance restoration method for pruned networks using knowledge distillation with synthetic data generated via network inversion
Saige Research Inc.
Implemented OCR models to automate manufacturing processes
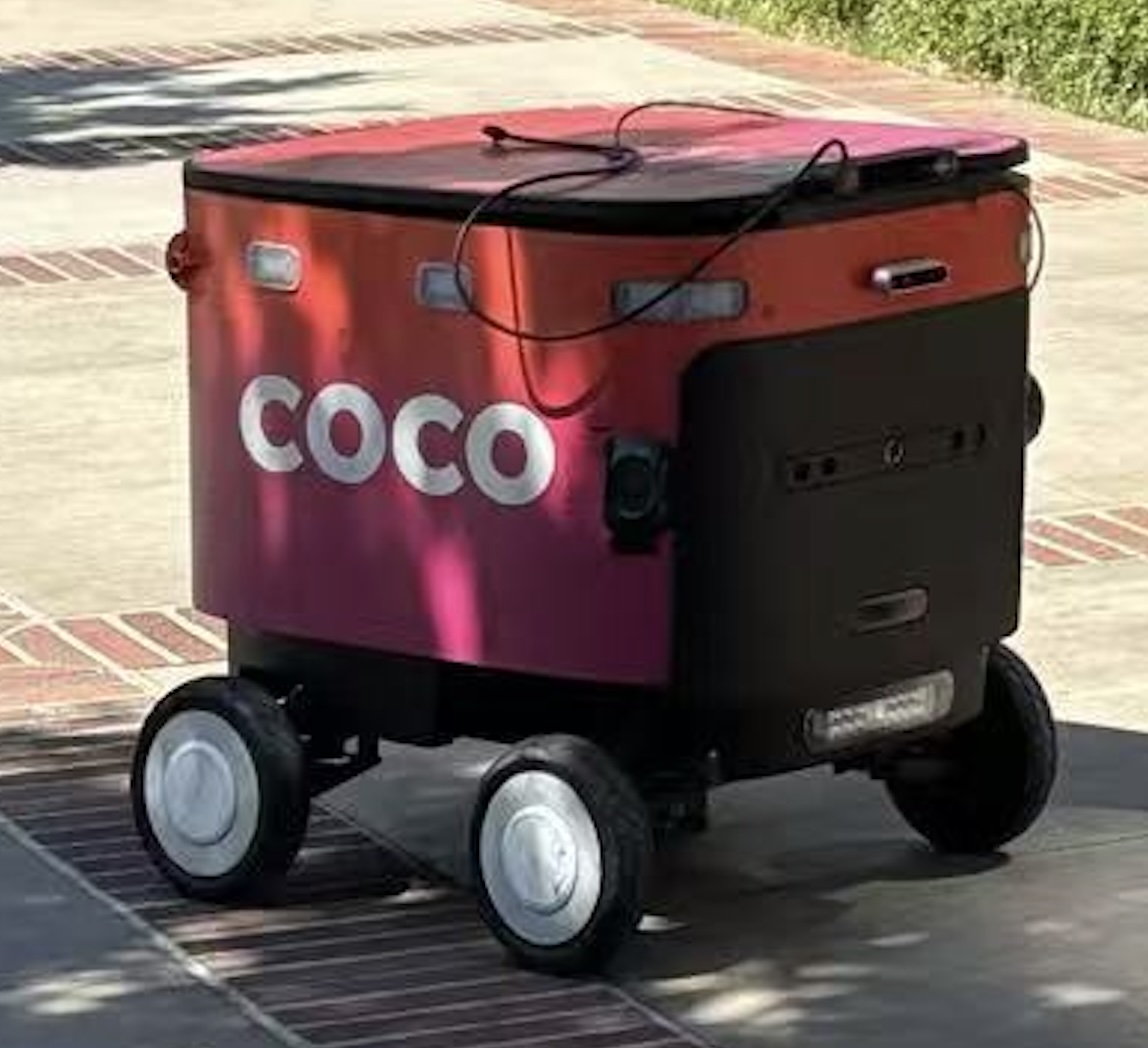
Enabling more intelligent driving for the COCO sidewalk delivery robot with a Vision-Language-Action policy refined by reinforcement learning for crowded urban sidewalks.
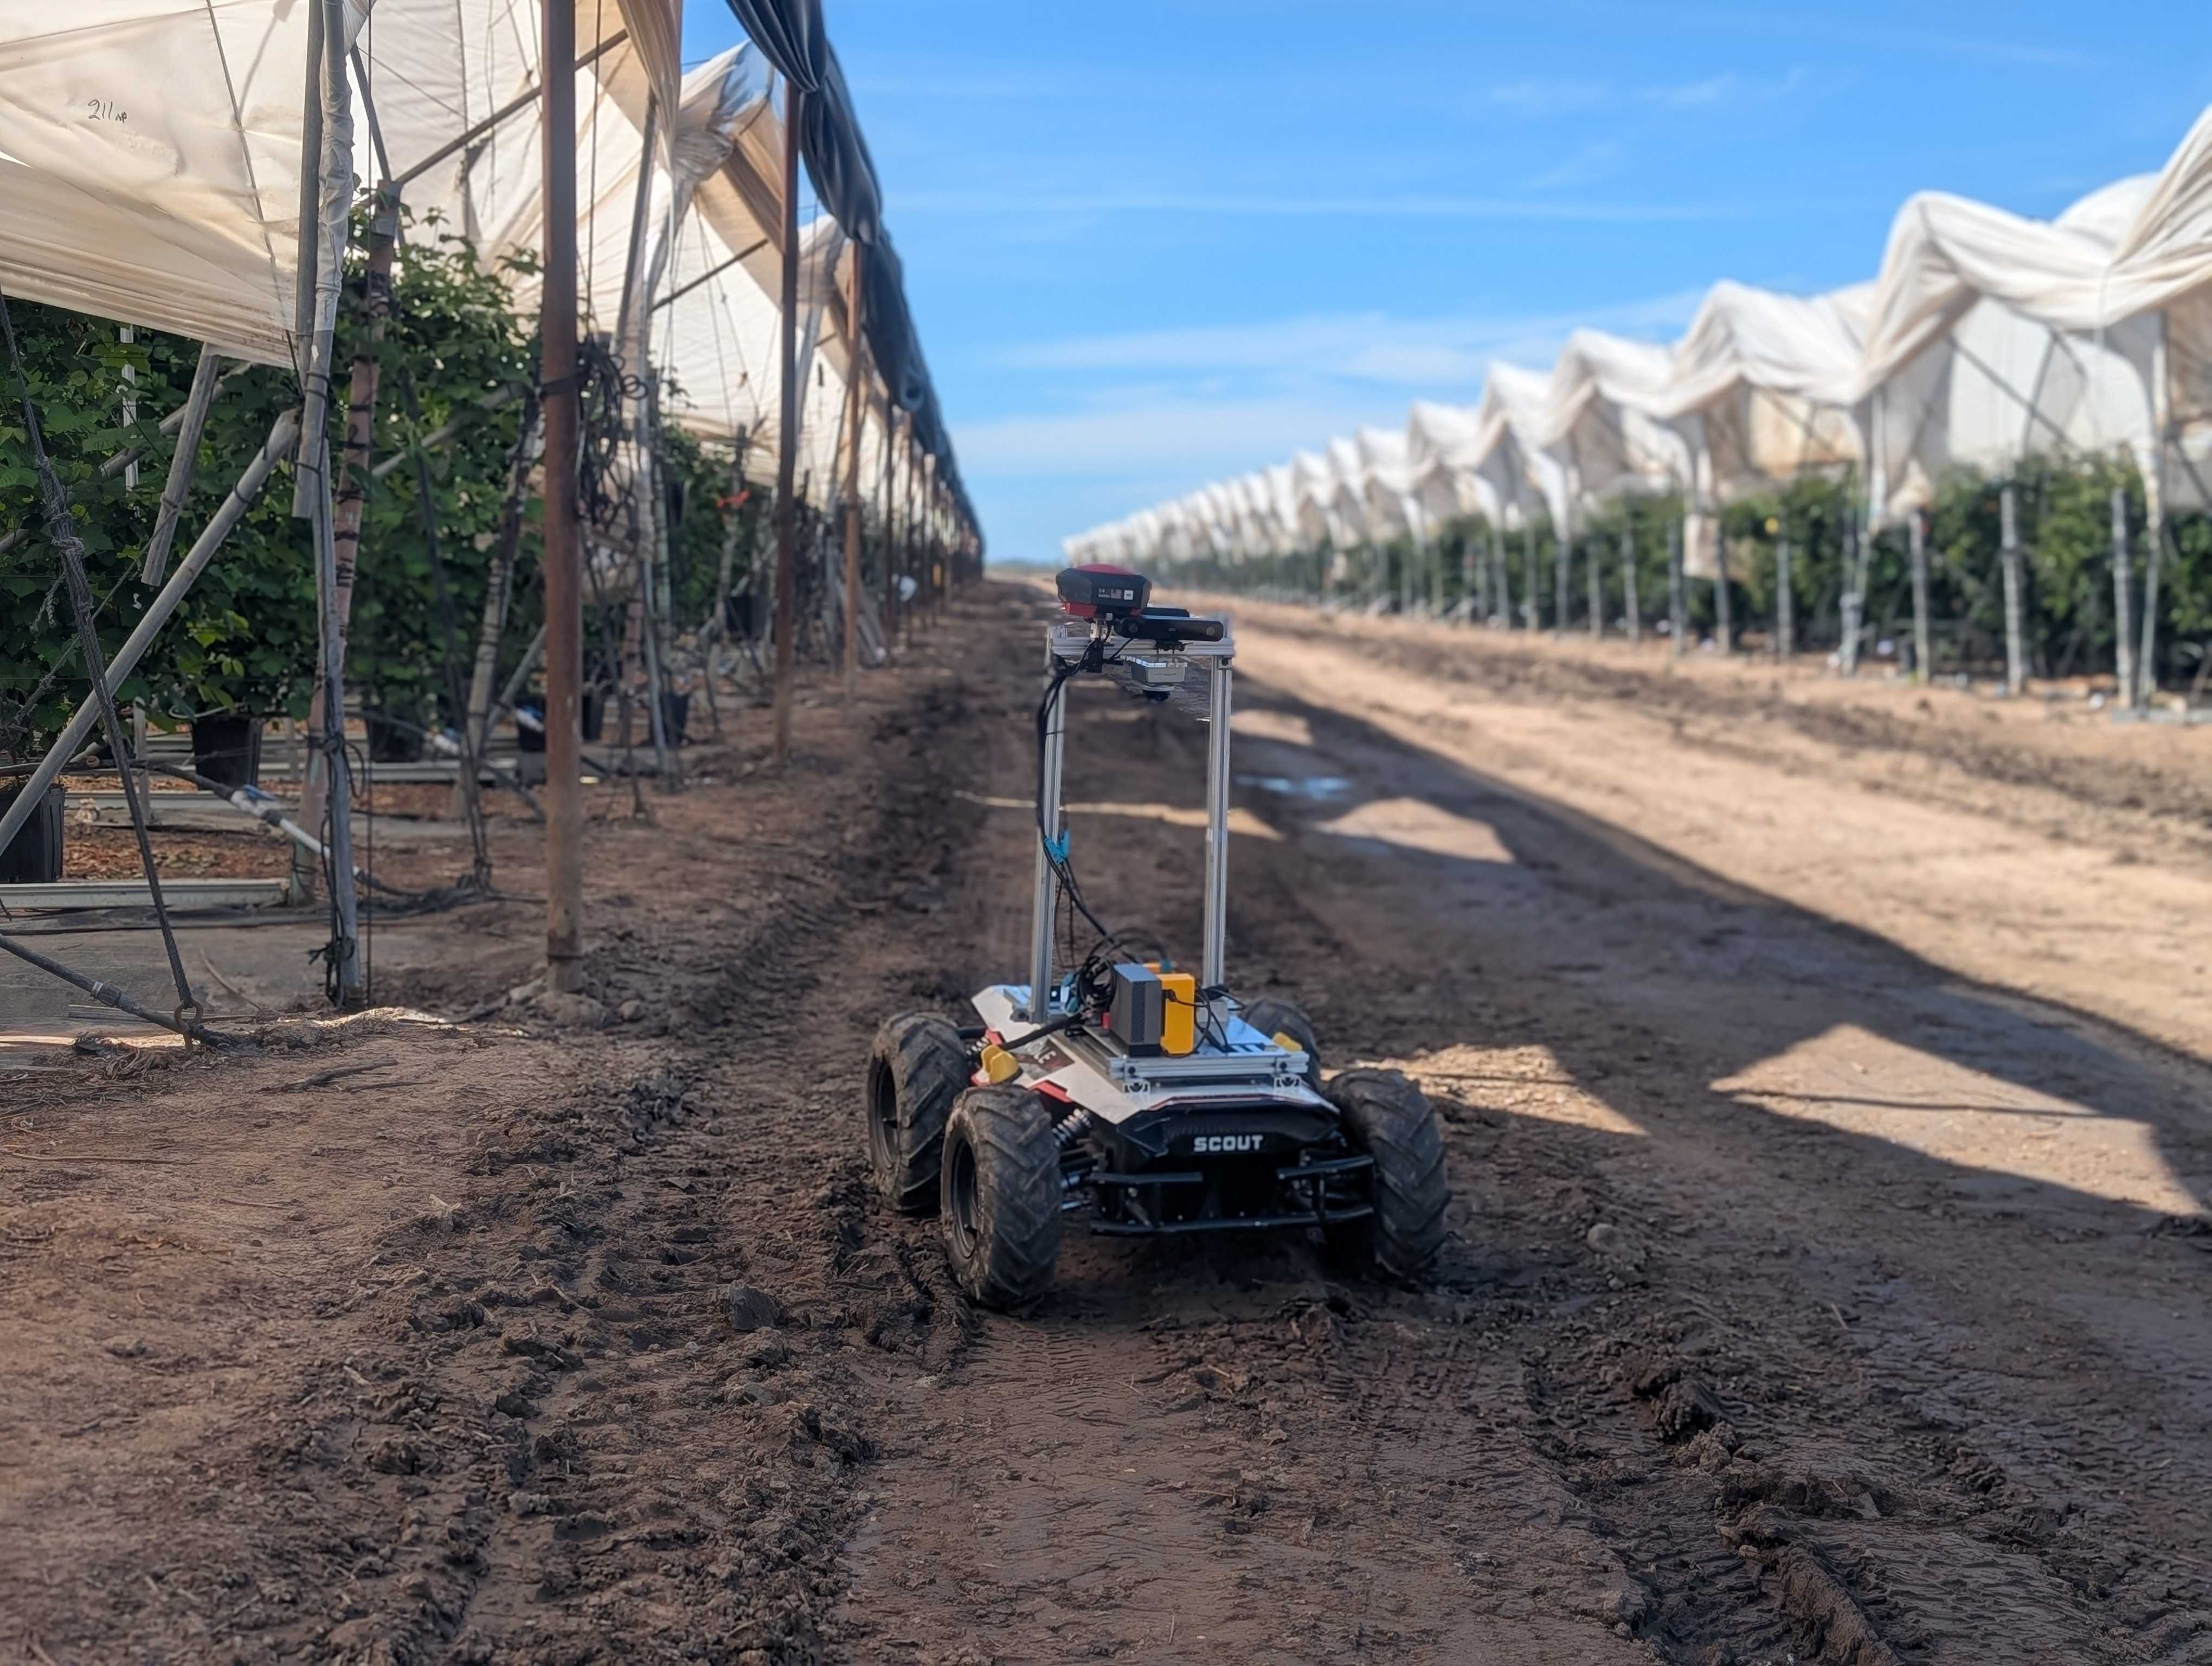
Field-deployed Vision-Language Navigation robot for kilometer-scale row-crop farms in Fargo, ND, fusing RGBD cameras, LiDAR, and RTK GNSS with LiDAR-inertial SLAM and Starlink/radio connectivity. Includes the AgriSC Benchmark, evaluating CLIP, OpenCLIP, DINOv2, EVA-CLIP, and SigLIP for semantic consistency across viewpoint, time, and space.
The framework, DiffusionMix, combines two Denoising Diffusion Probabilistic Models (DDPMs), with one specialized for background generation and the other for object, such as implant, generation along with corresponding segmentation masks, enabling controlled and realistic image composition.